Thakur, A., Kaipa, K., Banerjee, A. G., Cappelleri, D. J., Krovi, V. N., & Gupta, S. K. (2025). “Physical Artificial Intelligence for Powering the Next Revolution in Robotics.” Journal of Computing and Information Science in Engineering, 25(12), 120809. DOI: 10.1115/1.4070122.
When AI Enters the Physical World
Generative AI can write text, create images, and respond to complex questions. However, generating a convincing answer is not enough for a robot assembling components in a factory, moving among patients in a hospital, or harvesting crops in a field.
A robot must make decisions amid sensor noise, friction, limited battery capacity, communication delays, unexpected obstacles, and human movement. Its decisions do not remain as text on a screen. They become physical actions, and errors can result in defective products, damaged equipment, operational disruption, or harm to people.
In “Physical Artificial Intelligence for Powering the Next Revolution in Robotics,” Atul Thakur and his co-authors present physical AI as a foundational paradigm for the next generation of robotics. Rather than reporting the performance of a single model or robot, the paper is a position paper that synthesizes the definition, functional components, application domains, evaluation criteria, and future challenges of physical AI.
Physical AI Is More Than AI Installed in a Robot
The paper does not define physical AI simply as an artificial intelligence model placed inside a robotic platform. Its central idea is the continuous interaction among a robot’s body, sensors, controllers, learning algorithms, and physical environment.
Digital AI primarily operates on text, images, and structured data within virtual information spaces. Physical AI, by contrast, perceives the real world through sensors, makes decisions with incomplete information, and acts through physical actuators. The consequences of its actions return as new sensory data and modify subsequent decisions.
Intelligence, therefore, is not located solely in a central AI model. A robot’s morphology, joint structure, sensor placement, control architecture, operating environment, and interaction with humans all influence its intelligent behavior.
The authors position embodied intelligence as the broader cognitive and philosophical foundation, while describing physical AI as its engineering realization in robots and autonomous physical systems.
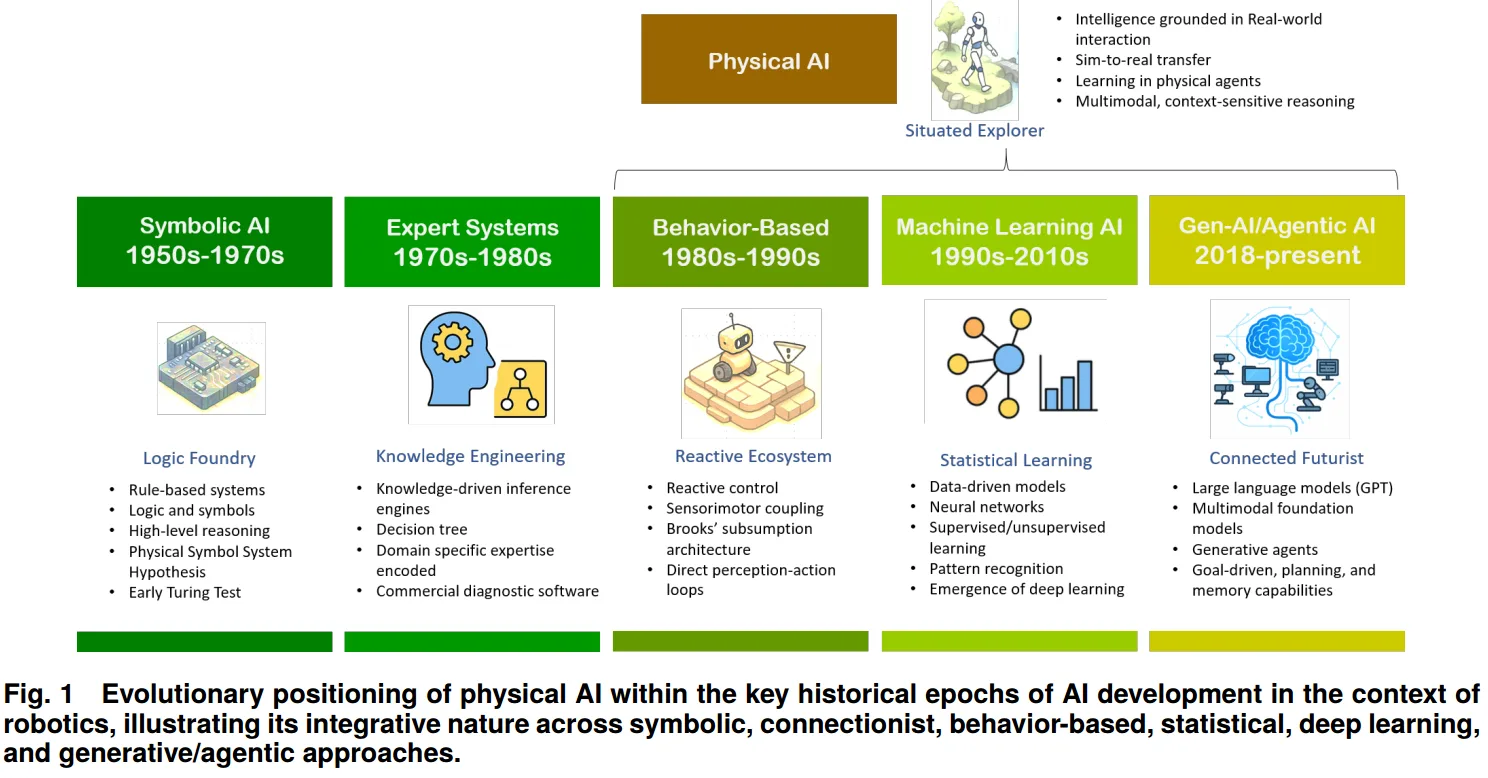
The Core Is a Closed Loop, Not a Single Model
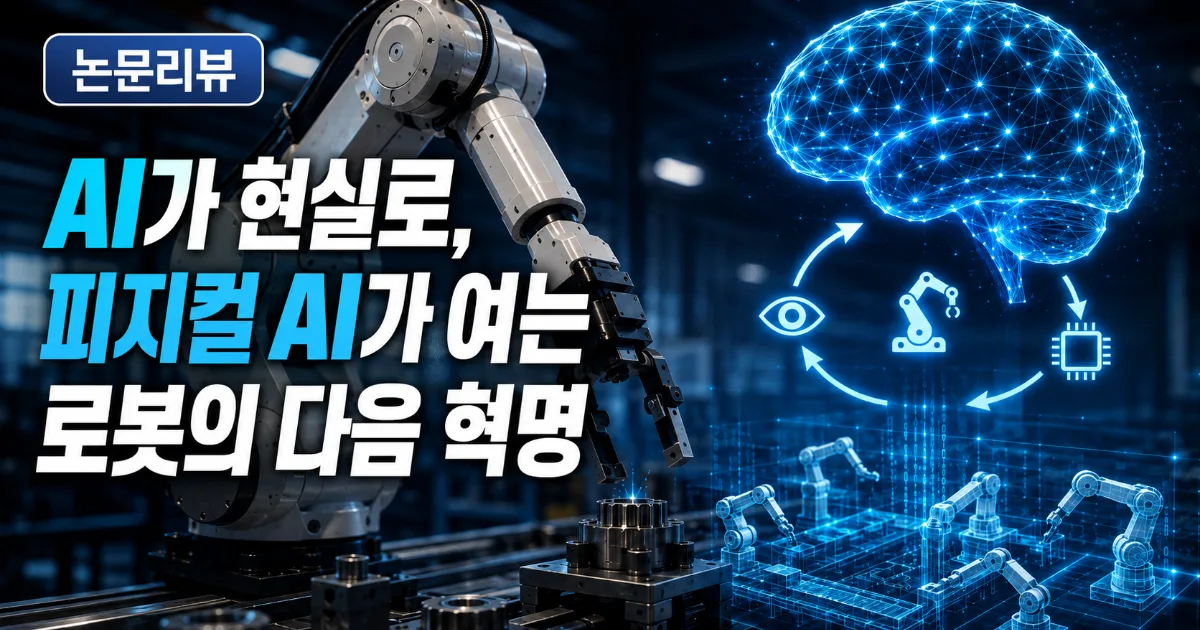
The architecture described in the paper resembles a connected closed loop rather than one enormous AI model.
A robot first perceives its surroundings through cameras, LiDAR, tactile sensors, and other sensory devices. It then estimates its own position, constructs a representation of the environment, and plans tasks and motion paths. After executing an action through its control system, it observes the result and corrects errors through further sensory feedback.
This loop includes situational awareness, localization and mapping, planning and reasoning, control and adaptation, imitation learning, and human–robot interaction. Even a large language model that translates natural-language instructions into robot actions remains only one component of this larger system.
Physical AI therefore cannot be evaluated solely by asking how intelligent or accurate its AI model is. Evaluation must also consider whether the system completes the real-world task, how quickly it responds, how safely it behaves under uncertainty, and whether humans can understand and override its decisions.
Digital Twins as Training and Validation Infrastructure
One of the paper’s most important arguments is that digital twins should be treated as essential infrastructure for physical AI.
Learning through repeated trials on a real robot is costly, slow, and potentially dangerous. A digital twin recreates the robot and its operating environment in a virtual space, allowing developers to simulate alternative actions and repeatedly test risky situations before physical deployment.
In this context, a digital twin is not merely a three-dimensional visualization. It is a synchronized virtual counterpart connected to sensor data, actuators, and control policies. It can reflect the system’s current state, test possible actions, detect faults, and support the transfer of learned policies to physical systems.
This transfer from virtual training to physical deployment is commonly described as sim-to-real. The robot learns and is validated in simulation before operating in the real world, while errors and data collected during physical operation are fed back into the digital twin.
The result is a continuous cycle of learning, prediction, execution, comparison, and correction.
Manufacturing Is the Most Demanding Test
Manufacturing clearly illustrates both the potential and the limitations of physical AI. Factories are relatively structured environments, but they impose extremely demanding requirements for quality, reliability, and safety.
The paper offers a memorable example. A robot with a 99% success rate at each step of a 200-step process would produce an average of two errors per product. A 99% performance level may appear impressive for a language model, but in manufacturing it can create rework, scrap, equipment damage, and production downtime.
For this reason, physical AI in manufacturing cannot rely entirely on end-to-end learning from massive datasets. It must combine physical models with data-driven learning, operate with limited and noisy data, and remain easily upgradable as equipment wears or production configurations change.
The authors also emphasize modular functional decomposition and clearly defined interfaces. A system should estimate uncertainty, request human intervention when risk is high, and explain why its behavior deviated from expectations.
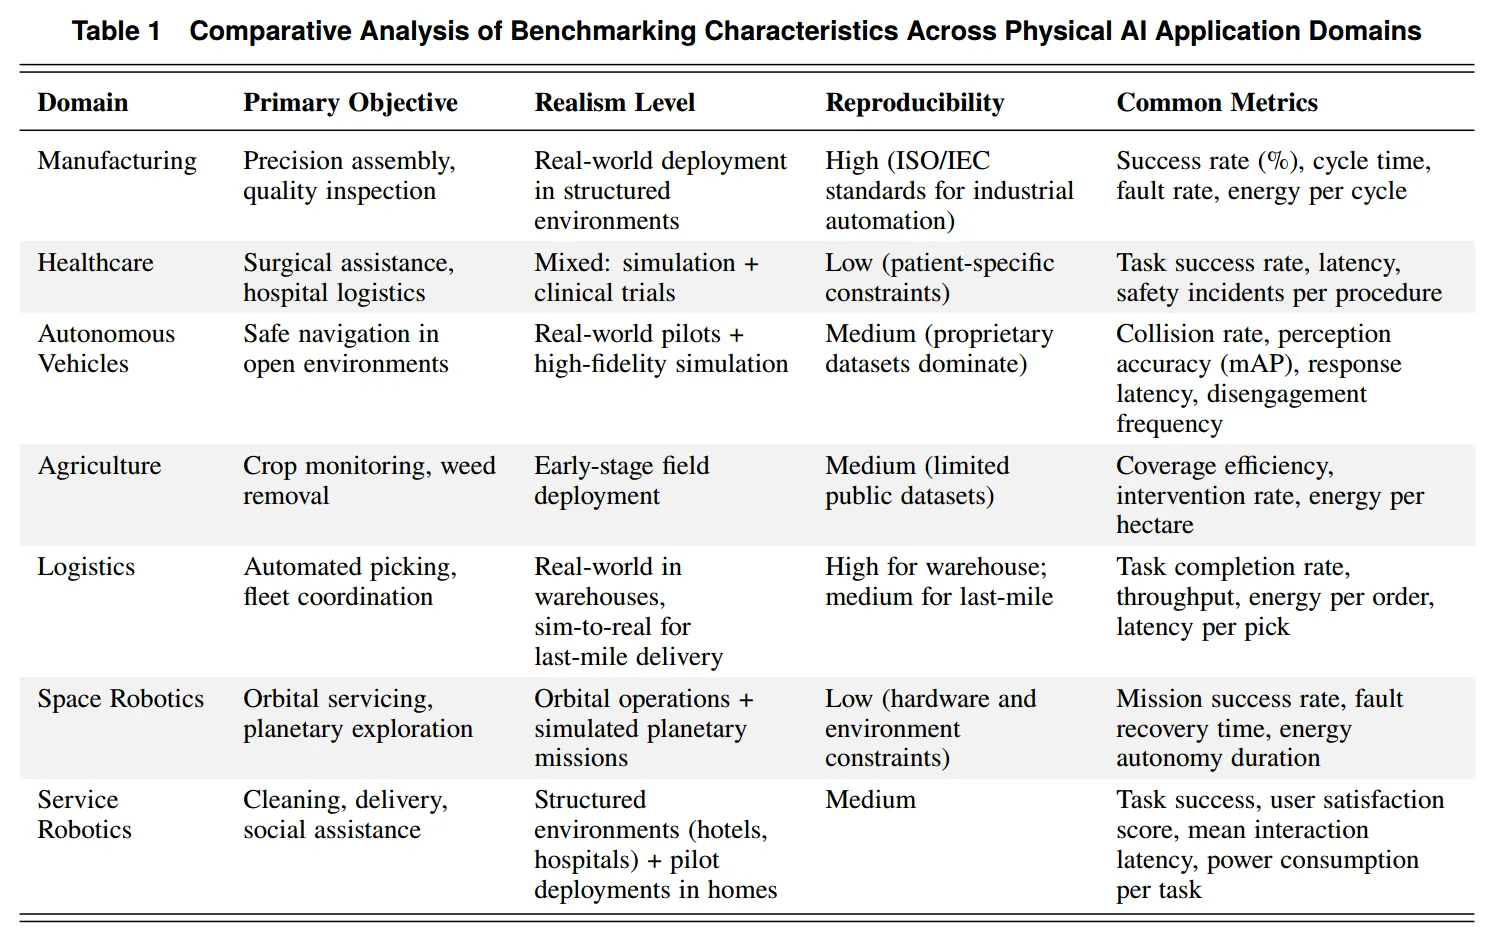
Manufacturing performance must therefore be measured through more than task accuracy. The paper identifies success rate, cycle time, fault rate, and energy consumption per cycle as representative indicators. The value of physical AI must be demonstrated not only technically, but also in productivity, operating efficiency, cost, and energy use.
Different Domains, Different Levels of Readiness
The paper compares physical AI across manufacturing, healthcare, autonomous vehicles, agriculture, logistics, space exploration, and service robotics.
Some applications in structured environments have already reached commercial deployment. Examples include autonomous mobile robots in warehouses and delivery robots operating within hospitals. In contrast, robots providing direct patient care, general-purpose household robots, and autonomous systems operating in extreme space environments still require substantially greater safety, adaptability, and reliability.
The relevant performance indicators also differ by domain. Manufacturing prioritizes precision and cycle time. Healthcare emphasizes safety incidents and response latency. Service robotics requires user satisfaction and interaction quality, while space robotics depends on mission success and fault-recovery time.
These differences demonstrate why physical AI cannot be judged through a single universal accuracy score. A layered evaluation framework is needed to assess task performance, system operation, and human interaction separately.
Six Barriers to Real-World Deployment
The authors identify six major challenges that must be addressed before physical AI can be deployed widely.
The first is real-time data processing. Robots must integrate and interpret streams of data from cameras and sensors with minimal delay. The second is energy efficiency, as complex AI models and continuous sensing can rapidly exhaust the batteries of mobile systems.
The third is cybersecurity. A compromised connected robot creates risks that extend beyond information leakage, because attackers may gain access to sensors, controllers, and actuators. The fourth challenge is scalable learning. Physical AI must overcome catastrophic forgetting, in which learning a new task degrades previously acquired abilities, as well as the sim-to-real gap between virtual training and physical operation.
The fifth challenge is safety. A physical AI system must recognize its own uncertainty and switch to conservative behavior, a fallback controller, or human intervention when risk becomes unacceptable.
The sixth is ethics. Physical AI raises questions involving personal data captured by cameras and microphones, accountability for physical harm, biased behavior, human autonomy, and alignment with social and human values.
Contributions and Limitations
The paper’s main contribution is its system-level interpretation of physical AI. Rather than reducing the concept to a particular technology or the current popularity of humanoid robots, it presents physical AI as an integrated paradigm connecting perception, planning, control, learning, embodiment, and interaction.
Its discussion of digital twins, sim-to-real transfer, human oversight, safety, explainability, and domain-specific performance indicators provides a valuable roadmap for moving physical AI beyond laboratory demonstrations and into real industrial environments.
The paper nevertheless has clear limitations. As a position paper, it does not empirically validate its proposed evaluation framework. Its domain-readiness diagrams are qualitative conceptual comparisons rather than results derived from quantitative measurements. The broad coverage of multiple sectors also limits the depth with which individual regulatory and technical contexts can be examined.
Despite these limitations, the paper makes a timely contribution by offering a shared vocabulary, functional architecture, and evaluation perspective for a field whose boundaries are still rapidly evolving.
Where Will the Next Robotics Revolution Begin?
Physical AI does not simply mean a robot equipped with AI. It requires the co-design of the robot’s body, sensors, control system, learning architecture, physical environment, human interaction, and digital twin as one continuous feedback system.
During the rise of generative AI, competitiveness was often measured by model size and the quantity of training data. Real-world robotics will likely be judged by a different set of questions.
Can the system perceive reality accurately? Does it understand its physical limits? Can it predict and validate the consequences of its actions? Can it stop safely in an unexpected situation? Can humans understand its reasoning and intervene when necessary?
The next robotics revolution will not begin when AI generates more answers. It will begin when intelligent systems can sense, decide, and act in the physical world—and remain accountable for the consequences of those actions.